Drifting Schools In Usa
Drifting Schools In Usa - Inertia drifting depends on two key factors: For large driving torque, two motions with rapid turning and large tire slips are possible: To that end, this paper describes a controller framework for automated drifting along a complex trajectory. The controller is derived for a generic path, without assuming operation near an. For small driving torque, the vehicle corners slowly with small tire slips. To create a big drift angle, brake before entering the corner and control the throttle to pass the clipping point with a big angle. For small driving torque, the vehicle corners slowly with small tire slips. Inertia drifting depends on two key factors: To create a big drift angle, brake before entering the corner and control the throttle to pass the clipping point with a big angle. To that end, this paper describes a controller framework for automated drifting along a complex trajectory. The. To that end, this paper describes a controller framework for automated drifting along a complex trajectory. For small driving torque, the vehicle corners slowly with small tire slips. The controller is derived for a generic path, without assuming operation near an. To create a big drift angle, brake before entering the corner and control the throttle to pass the clipping. Inertia drifting depends on two key factors: To that end, this paper describes a controller framework for automated drifting along a complex trajectory. For large driving torque, two motions with rapid turning and large tire slips are possible: The controller is derived for a generic path, without assuming operation near an. To create a big drift angle, brake before entering. To that end, this paper describes a controller framework for automated drifting along a complex trajectory. For large driving torque, two motions with rapid turning and large tire slips are possible: The controller is derived for a generic path, without assuming operation near an. For small driving torque, the vehicle corners slowly with small tire slips. To create a big. Inertia drifting depends on two key factors: To create a big drift angle, brake before entering the corner and control the throttle to pass the clipping point with a big angle. To that end, this paper describes a controller framework for automated drifting along a complex trajectory. The controller is derived for a generic path, without assuming operation near an.. To that end, this paper describes a controller framework for automated drifting along a complex trajectory. Inertia drifting depends on two key factors: For large driving torque, two motions with rapid turning and large tire slips are possible: The controller is derived for a generic path, without assuming operation near an.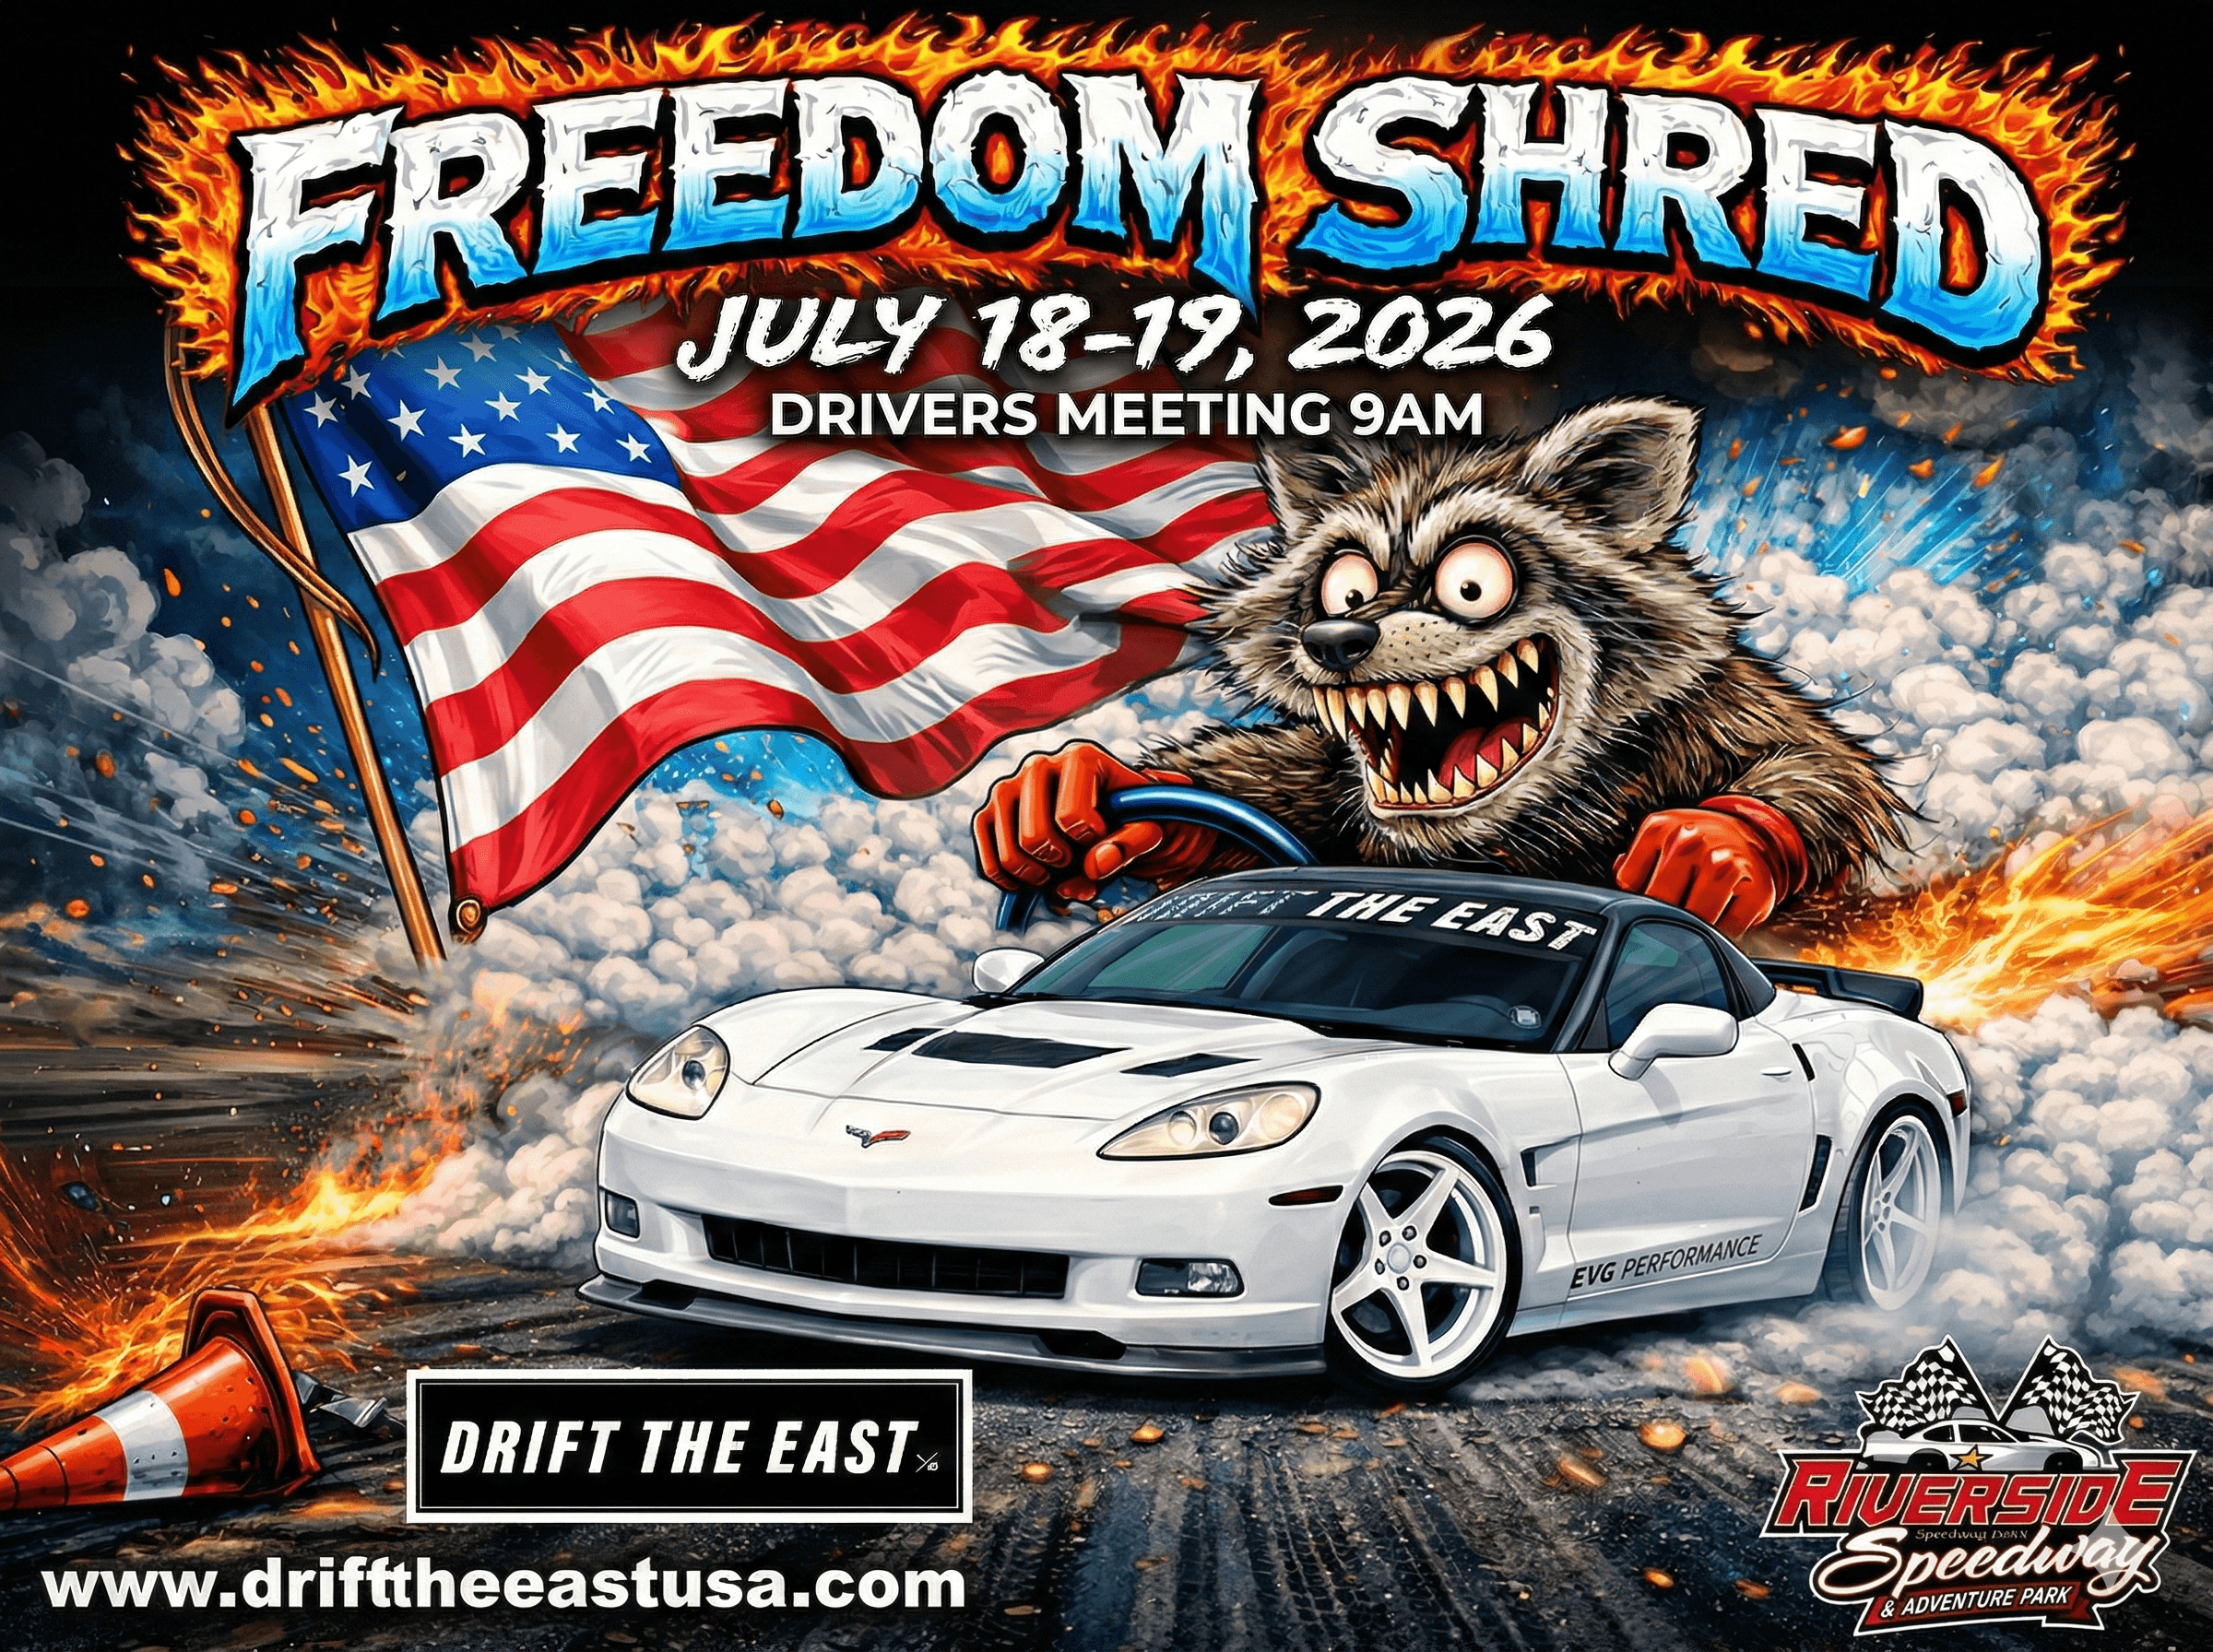
Drift The East New England Drifting Events & Drift School
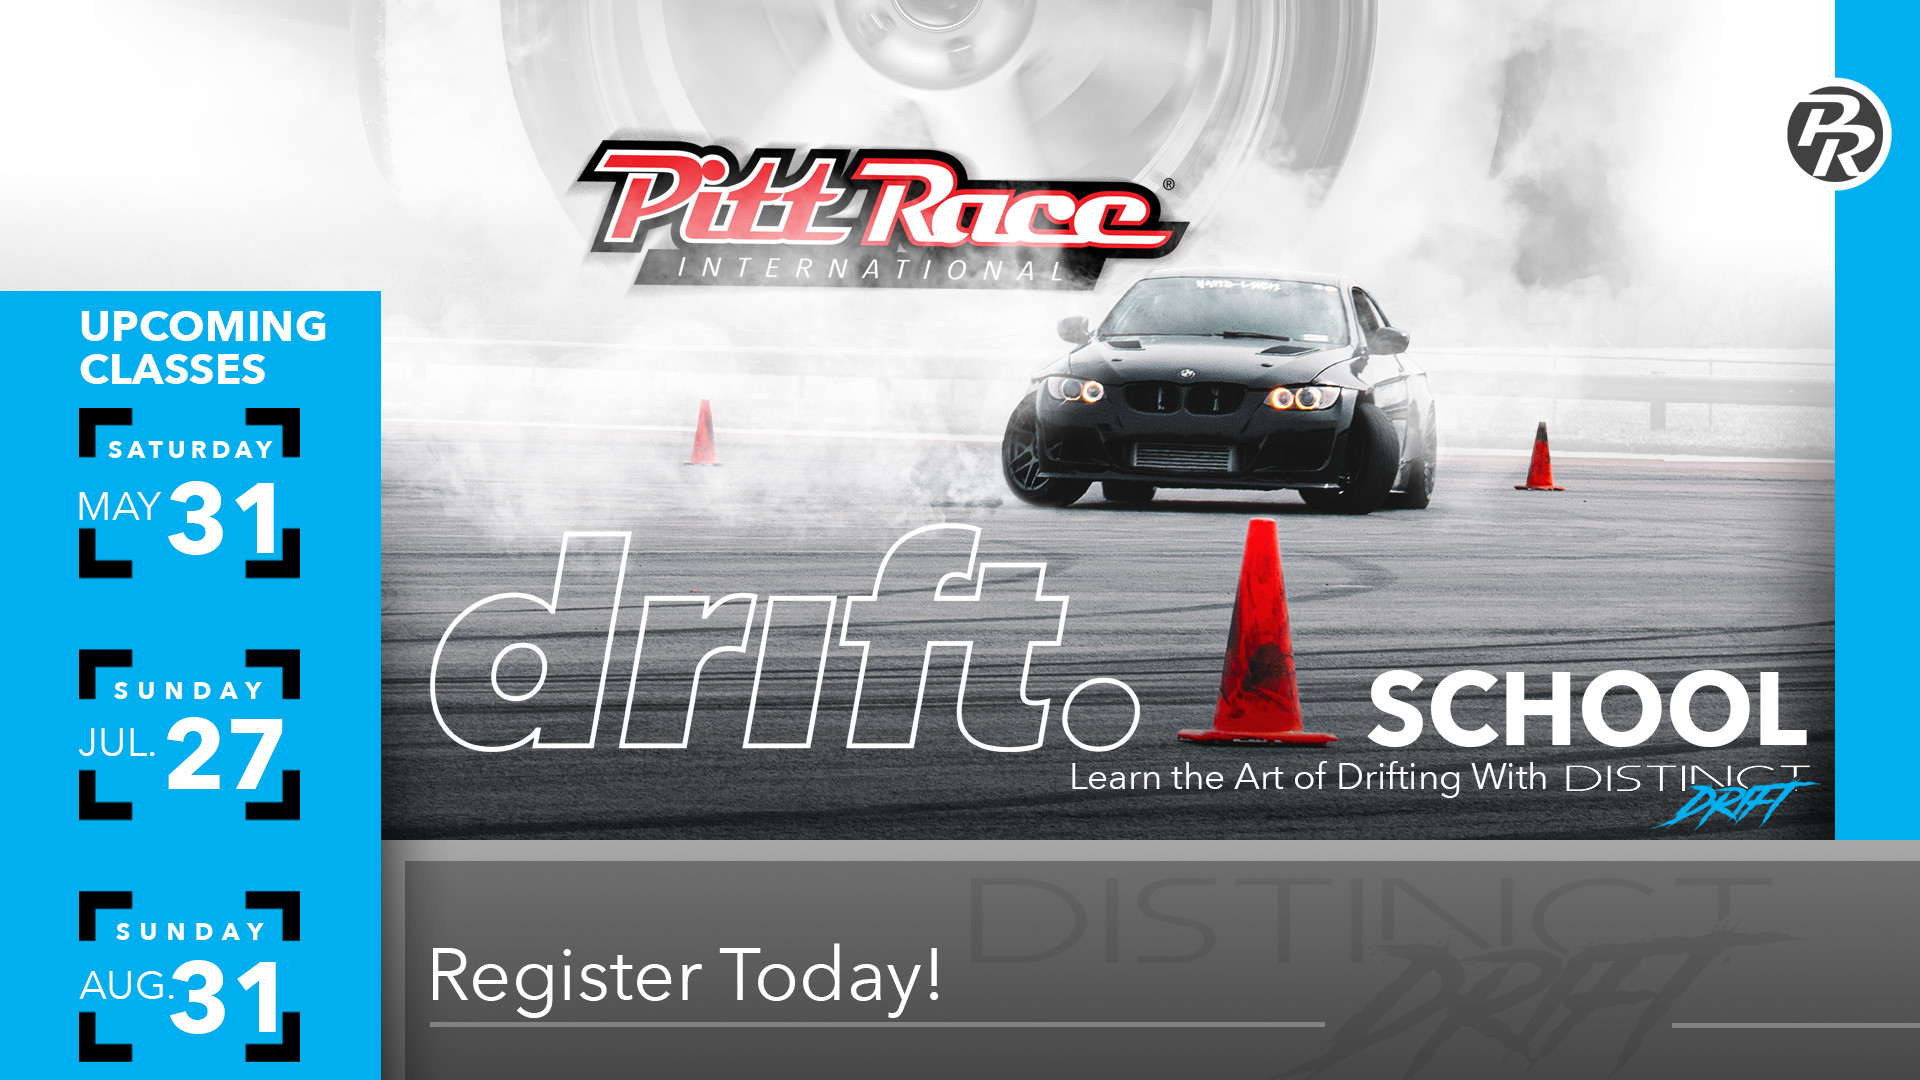
Drift School Pitt Race
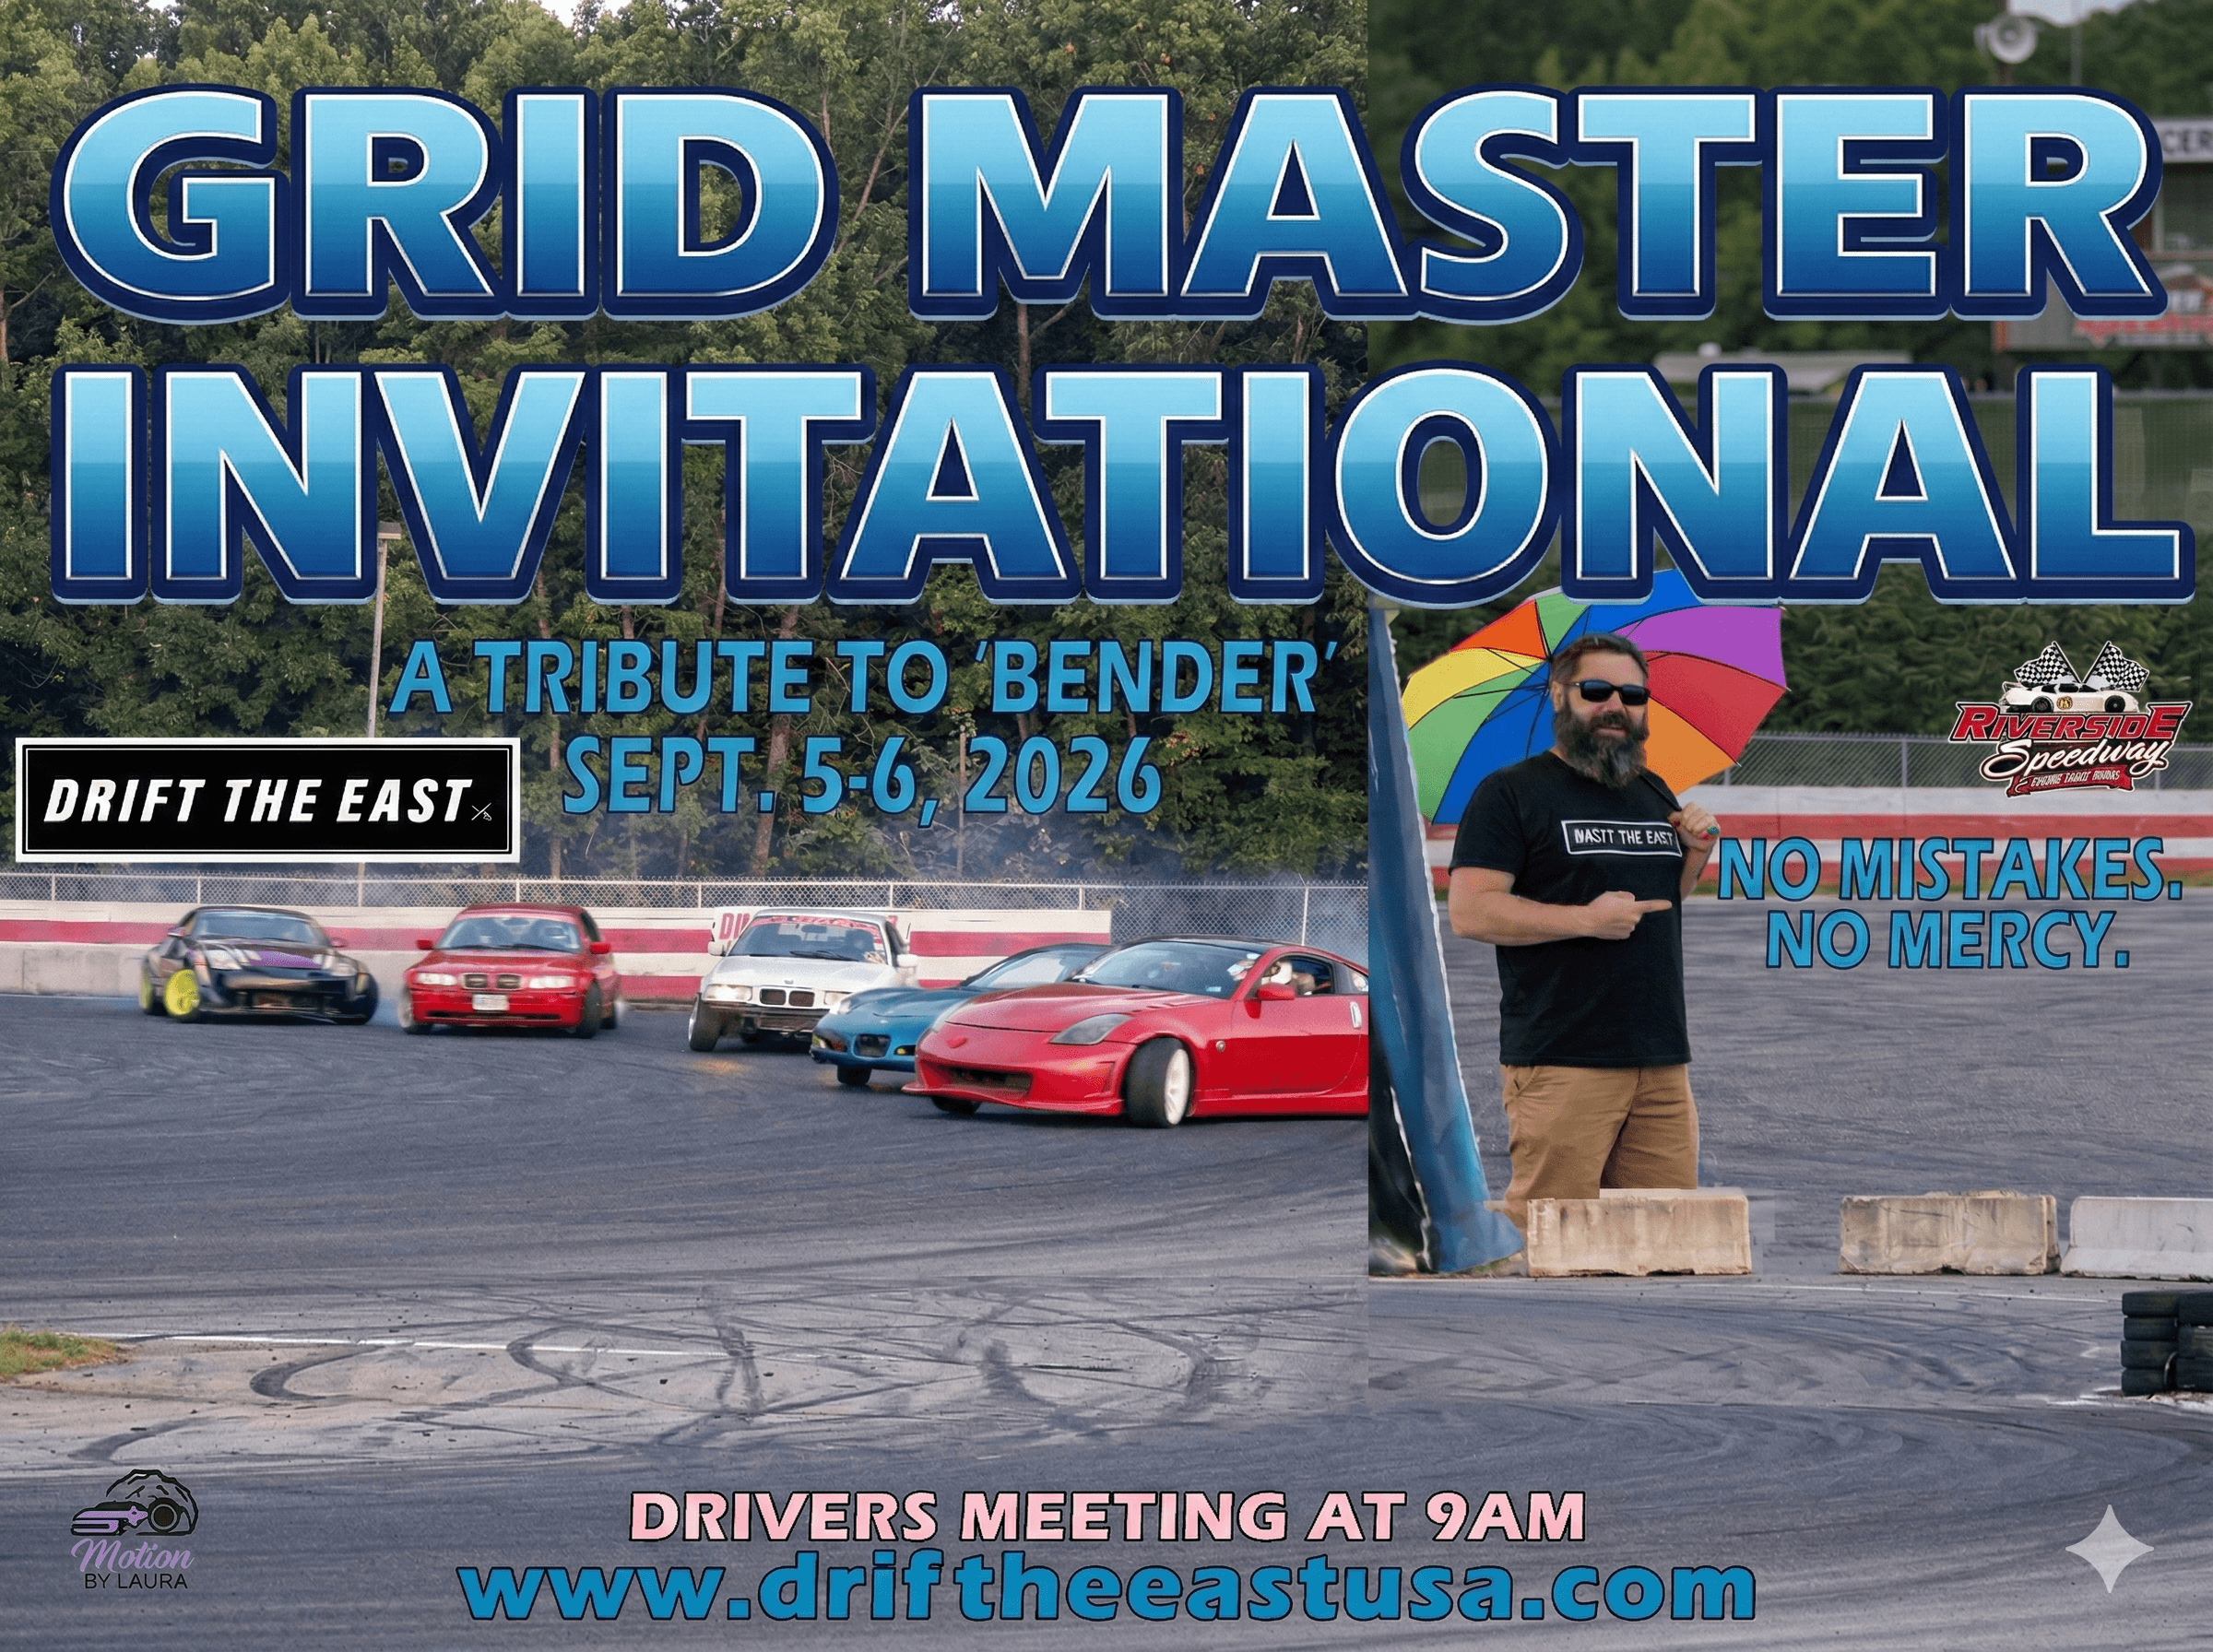
Drift The East New England Drifting Events & Drift School
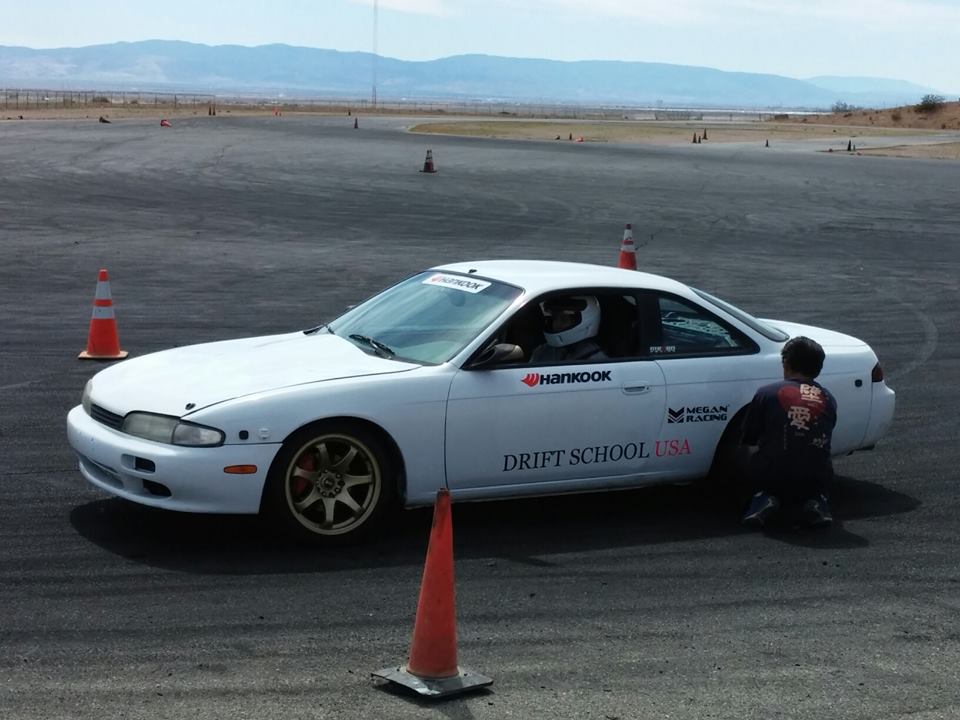
DriftSchoolUSA

Newark Truck Driving School 160 Driving Academy
For Small Driving Torque, The Vehicle Corners Slowly With Small Tire Slips.
To Create A Big Drift Angle, Brake Before Entering The Corner And Control The Throttle To Pass The Clipping Point With A Big Angle.
Related Post: